
Case Studies
Virtual Pre-Production for Netflix's Monster: The Lizzie Borden Story.
Reality capture let Netflix's Monster scout 35 Italian locations in four days with PortalCam, then plan shots remotely through virtual scouting of 3DGS scans.
Parking Lot 3D Scanning and Mapping involves data collection and annotating information about parking spaces, lanes, entrances, ground markings, etc.,
Parking Lot 3D Scanning and Mapping involves data collection and annotating information about parking spaces, lanes, entrances, ground markings, etc., to assist management in improving operational efficiency and providing intelligent services such as automated parking, smart guidance, and reverse car search through 3D visualization.
Traditional parking lot surveys primarily rely on total stations and manual measurements, resulting in low efficiency and potential disruptions to normal parking operations. This is particularly challenging for large-scale parking lots associated with shopping malls, residential areas, and public facilities.
Lixel L1 features real-time modeling, high precision, portability, and ease of use. It can rapidly acquire point cloud data for parking lots, enabling the creation of CAD drawings and BIM models. This facilitates the digital upgrade of parking lots with reliable data.
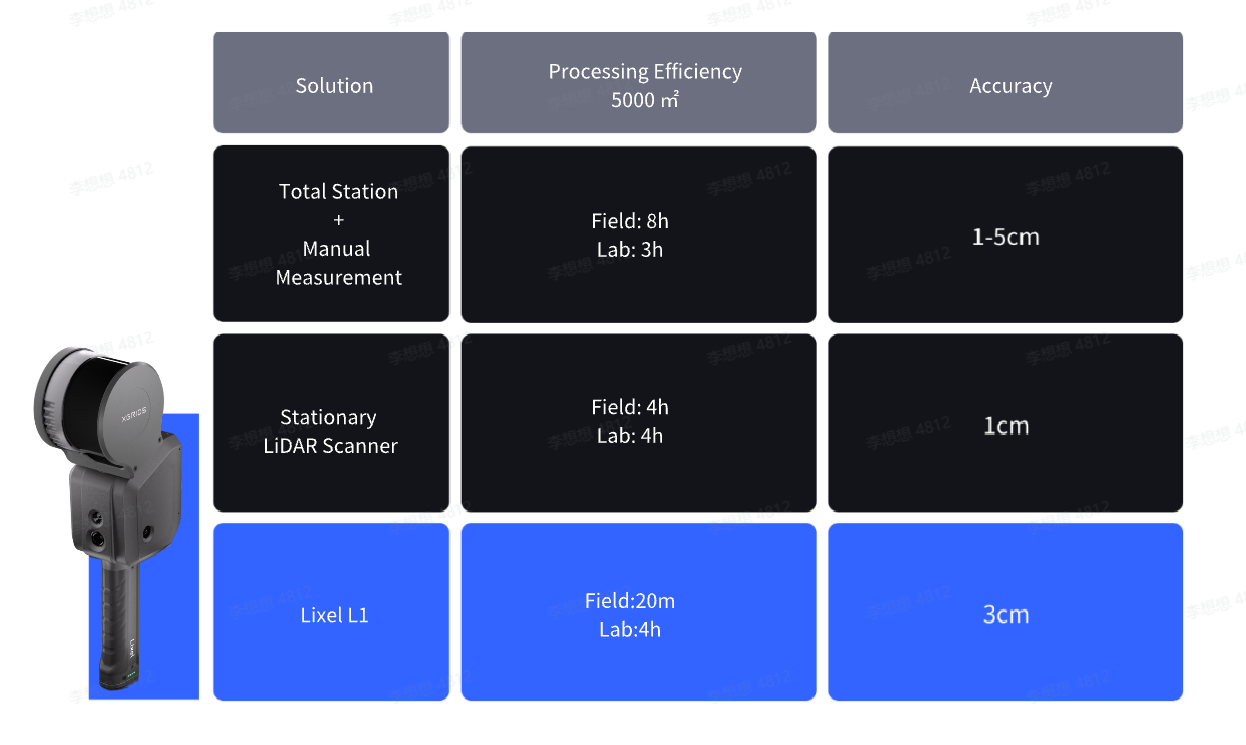
| Solution | Processing Efficiency 5000 ㎡ | Accuracy |
| Total Station + Manual Measurement | Field: 8h Lab: 3h | 1-5cm |
| Stationary LiDAR Scanner | Field: 4h Lab: 4h | 1cm |
| Lixel L1 | Field:20m Lab:4h | 3cm |
Before scanning, confirm the device battery, storage, and firmware, and walk the site to check lighting, obstacles, and traffic conditions so the parking lot can be captured in one continuous session.
Once the customer's scan needs are determined, scanning paths need to be planned in advance to ensure complete coverage of all areas in the underground parking lot. The path planning in the parking lot generally follows the principles of "overall first, then detail" and "big loop, small loop." It is necessary to perform an initial overall scan of the parking lot to ensure the integrity of the main structure. After that, a detailed scan of the parking lot's specific details can be conducted.
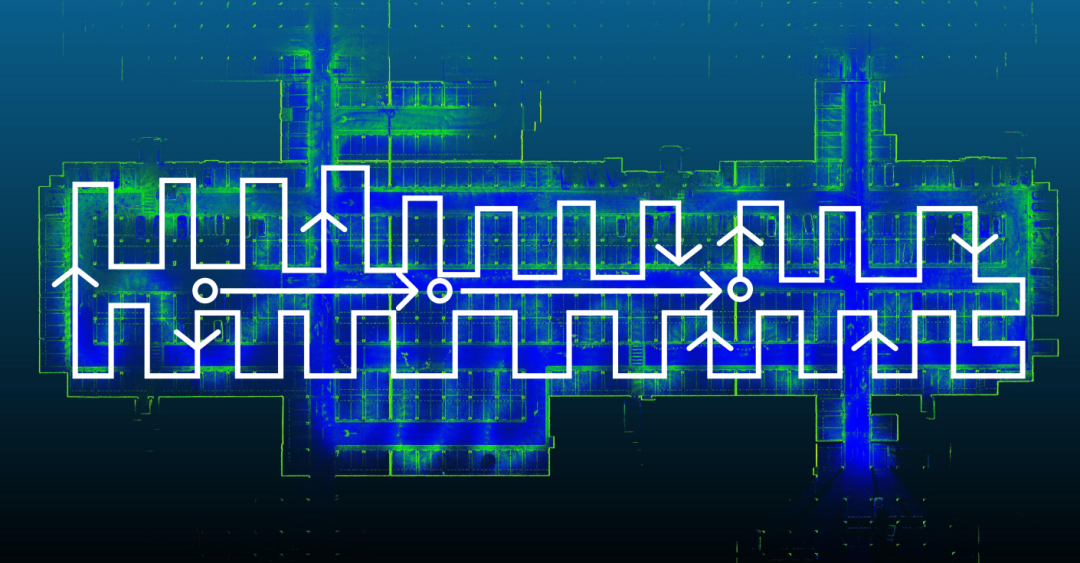
▲Typical route planning
Start by walking slowly along the centerline of the parking lot, roughly scanning the spatial structure in front, behind, left, and right. When you reach the third point, you will obtain the overall structure of this part of the parking lot. Then, follow an S-shaped route to scan the detailed parts of the parking lot. This collection method can provide a high-precision, detailed point cloud of the parking lot.
To better align the scan data in later data processing, a set of control points with known coordinates needs to be prepared. Coordinates can be obtained through a total station, GPS, or other devices, and their coordinates are accurate in a known coordinate system.
Scan according to the planned route. During the scanning process, use the Lixel L1 control point base to mark known coordinate points. It is important to note that underground parking lots usually have complex structures and environments, which may involve issues such as occlusion, reflection, and insufficient lighting. Multiple scans may be required to cover all corners and details.
Additional considerations:
1. Avoid sudden stops, turns, and rapid movements. It is recommended to walk at a speed of about 1m/s, and turn at a speed below 30 degrees per second.
2. At intersections, tilt the device forward by 45 degrees and slowly scan all intersections.
3. Single-person operation is recommended, or reduce the number of personnel accompanying the collection to minimize human shadow noise in the point cloud.
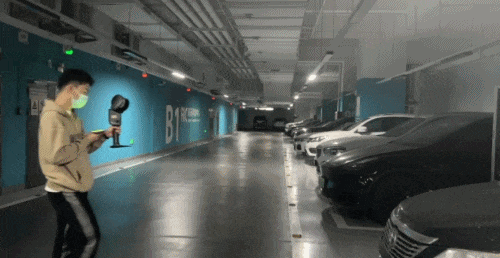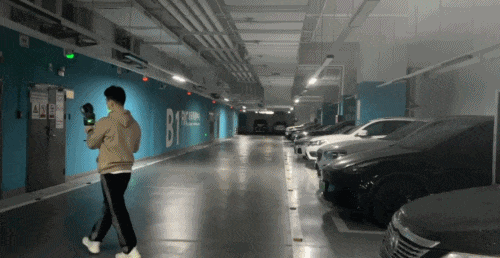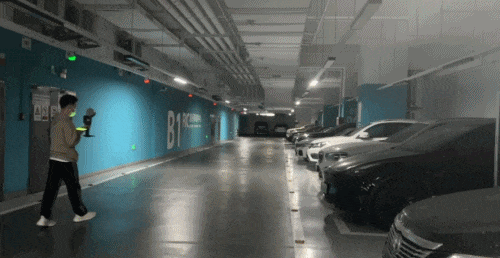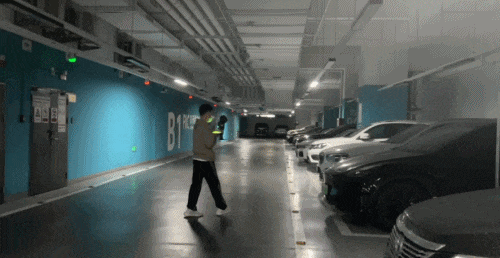
During the collection process, control points can be placed at several positions in the parking lot. Use the Lixel L1 control point base to align these points for absolute accuracy in indoor positioning.
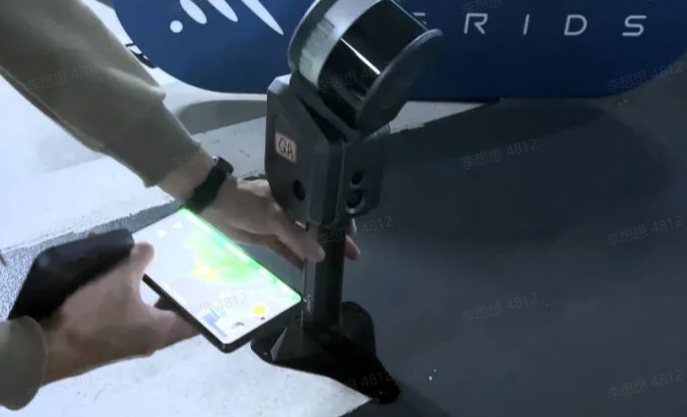
▲Marking of control points
After scanning, export the point cloud data collected by Lixel L1 and preliminary processing such as smoothing and noise reduction in LixelStudio to improve data quality and accuracy while reducing the file size.
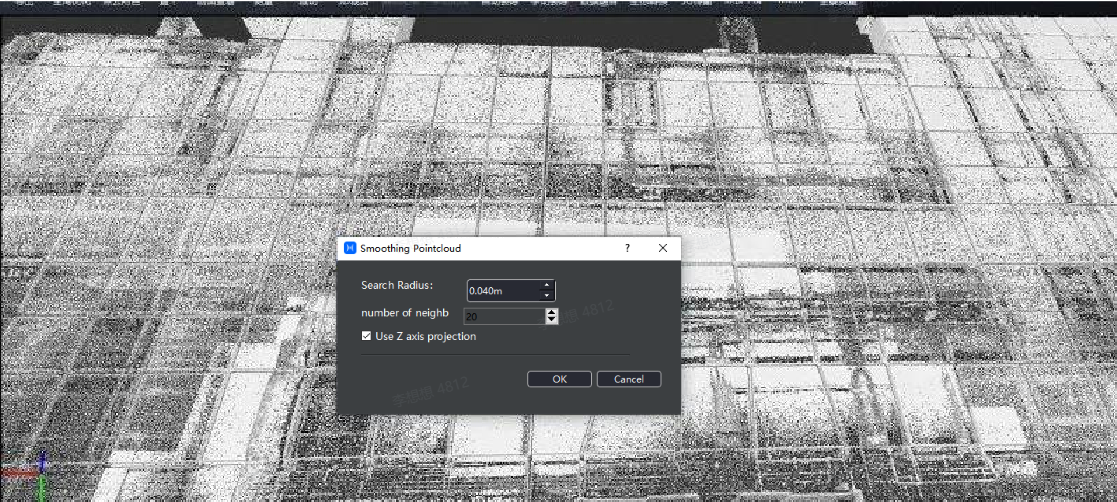
Based on the control points with known coordinates (measured by total station, RTK, or other devices), coordinate transformation is achieved through data alignment, coordinate conversion, verification, and adjustment.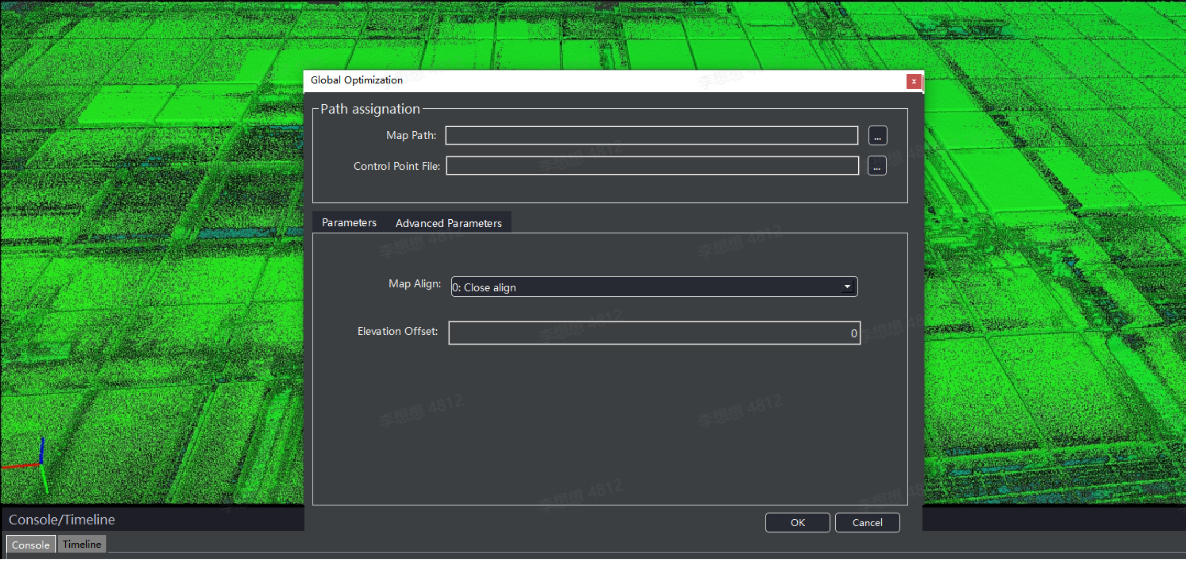
Use Recap to create an .rcp index file for CAD-compatible las data.
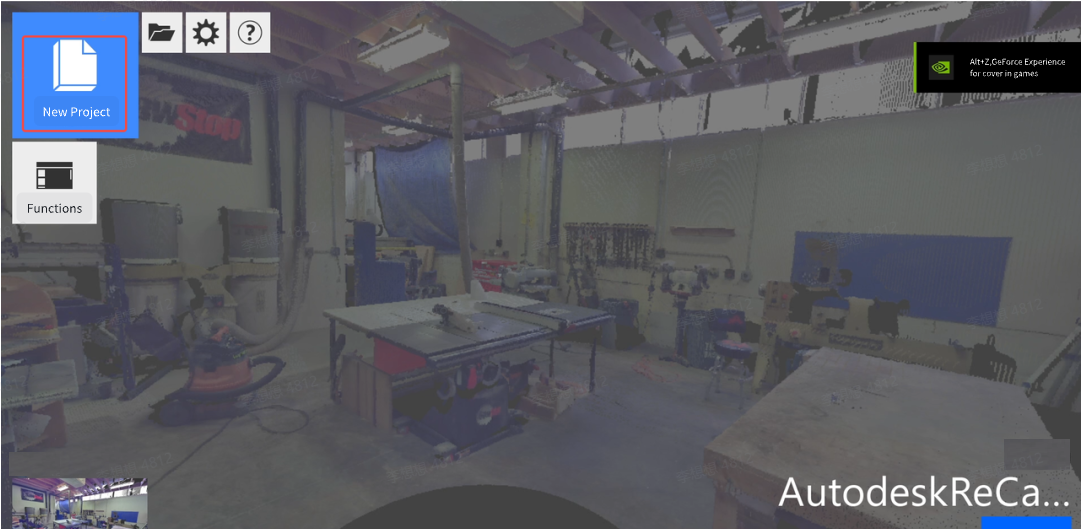
Import point cloud data into Autodest CAD, correct the orientation of the point cloud, and make line drawings based on point cloud reflectance color and required features.
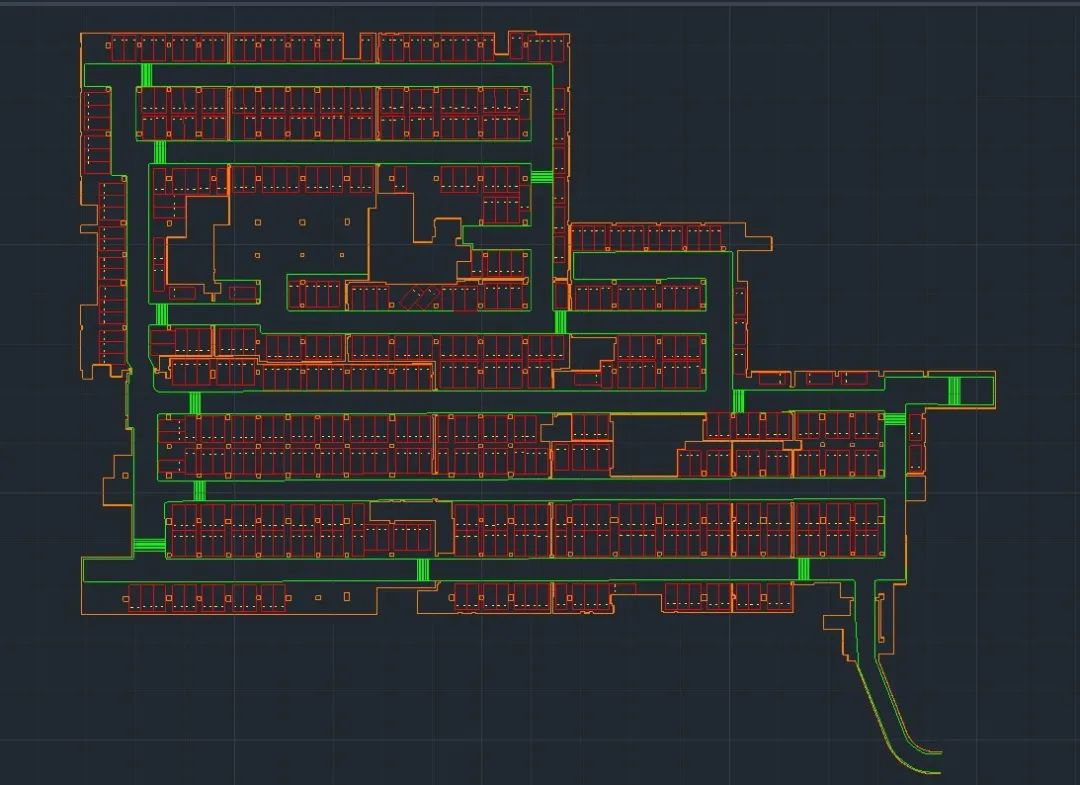
▲Draw features needed with reflectance point cloud as reference
After completing the drawing of key features, it is necessary to create the final drawing according to the project's drawing specifications, including sheet size, fonts, scale, symbols, axis lines, building material samples, drawing methods, dimension markings, and other specific requirements.
▲Point cloud overlaid wireframe
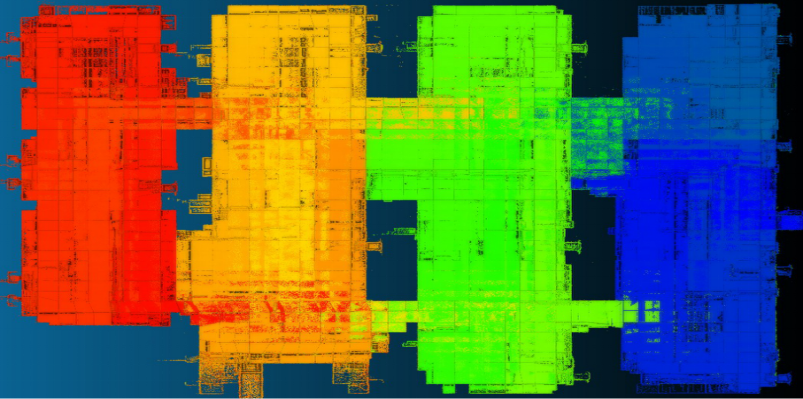
▲CAD results
Export the processed 3D model in order to do further analysis, measurement, and visualization in other software. Use the model to analyze the structure of the underground parking lot for safety assessments, planning, or other applications.
Accuracy Result 1:
An uninterrupted scan of a 50,000㎡ underground parking lot with horizontal and vertical accuracy better than 10cm.
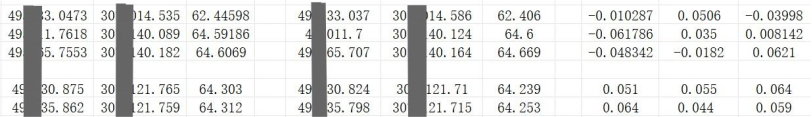
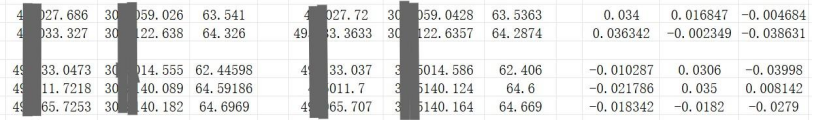
Accuracy Result 2:
An uninterrupted scan of a 15,000㎡ underground parking lot with horizontal and vertical accuracy better than 5cm.
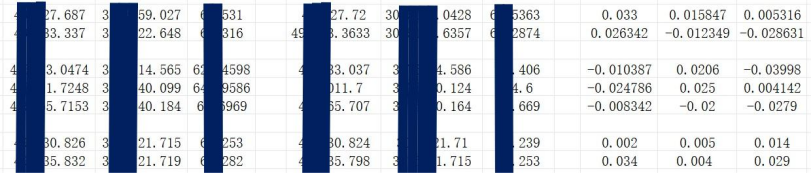
Accuracy Result 3:
An uninterrupted scan of a 6,000㎡ underground parking lot with horizontal accuracy better than 2cm and vertical accuracy better than 3cm.
Quickly obtain accurate information about urban parking lots, providing a data foundation for traffic planning, site design, urban construction, fire safety, and other follow-up work.
Provide a cm-level digital map for parking lots, supporting intelligent functions such as automatic parking, reverse car search, lane-level guidance, and parking space reservation. Create a seamless parking experience and improve parking lot operational efficiency.
Annotate all information about the parking lot, including parking spaces, entrances and exits, elevators, etc., on a three-dimensional map, providing complete information guidance for customers and visitors.
Reality capture let Netflix's Monster scout 35 Italian locations in four days with PortalCam, then plan shots remotely through virtual scouting of 3DGS scans.
.png?x-oss-process=image/resize,w_800/quality,Q_50)
A one-hour Lixel K1 scan of six Culver City blocks gave a generative film pipeline the fixed geometry it needed to keep six locations consistent.

Handheld 3DGS by PortalCam helped CyArk document three landmark interiors for America 250, solving mirror reflections and low-light field challenges.

Handheld 3D capture brings real museum spaces to LED volumes, replacing green screens and photogrammetry for fast, cinematic virtual camera moves.