Events & Webinars
Webinar Recap: 3DGS for Virtual Production: Capture, Craft, and Create
How 3D Gaussian Splatting is closing the gap between spatial capture and in-engine virtual production
XGRIDS at NVIDIA GTC 2026: Bridging Real-World Spaces and Physical AI Through Real2Sim
For robots to operate reliably in the real world, they need to train in environments that accurately represent it. That's the core problem behind Real2Sim — converting physical spaces into simulation-ready 3D environments — and it's what XGRIDS presented at NVIDIA GTC 2026 (March 16–19, San Jose).
XGRIDS' spatial intelligence solution now supports NVIDIA Omniverse NuRec for OpenUSD-based rendering and appeared across multiple GTC venues: a featured presentation during Startup Pitch, a solution showcase as part of NVIDIA’s Robotics demonstrations, and a joint demonstration with Amazon Web Services (AWS).
XGRIDS Director of Global Sales & Marketing Sunny Liao presented the company's Real2Sim solution during Startup Pitch, centered on a specific question: when intelligent agents need to operate in physical environments, how do you build training environments that faithfully represent reality?
XGRIDS' answer is a pipeline driven by real-world data. Through multimodal spatial perception — combining LiDAR with computer vision — and high-fidelity 3D reconstruction, real environments are converted into world models usable for simulation training.
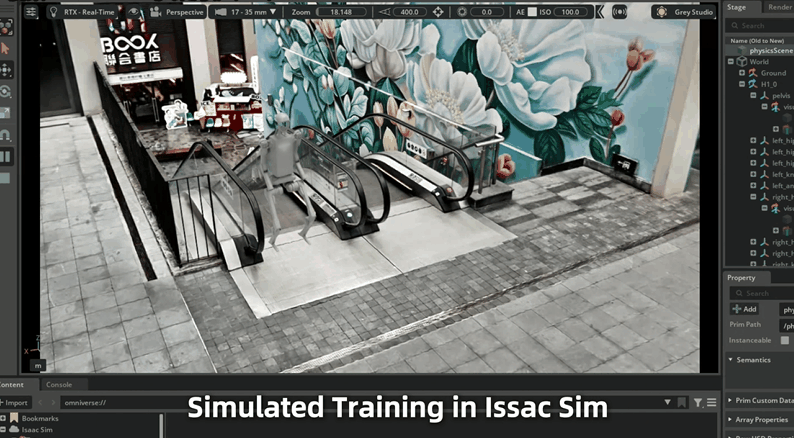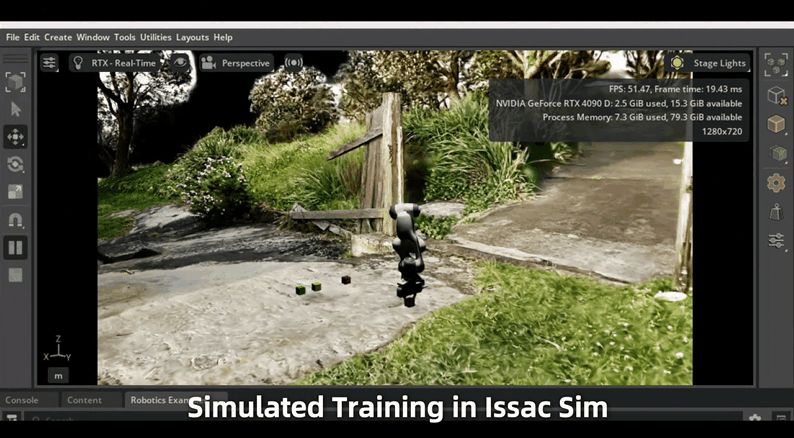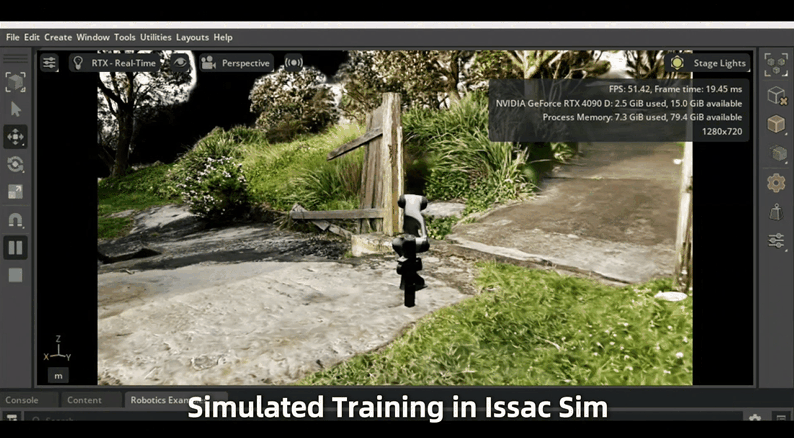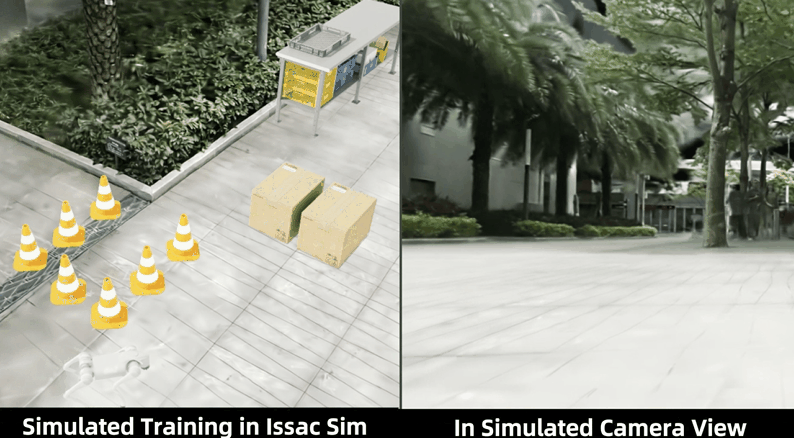
Compared to traditional manual 3D modeling, this pipeline significantly reduces the cost of building high-fidelity training scenes and allows environments to be continuously updated as physical spaces change — keeping training conditions closer to actual deployment.
In post-session conversations, developers and ecosystem partners noted that generating simulation environments directly from real-world spatial captures offers a more practical path for robot training and system validation than manual scene construction.
Beyond the Inception stage, XGRIDS' solutions appeared at multiple showcase areas across GTC.
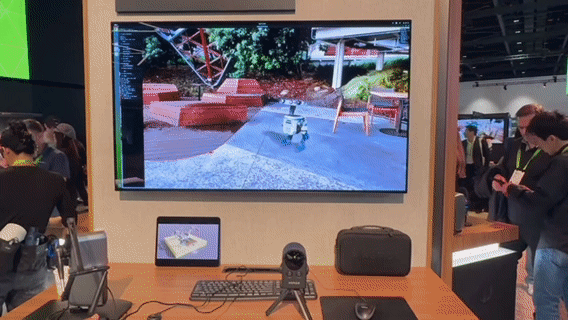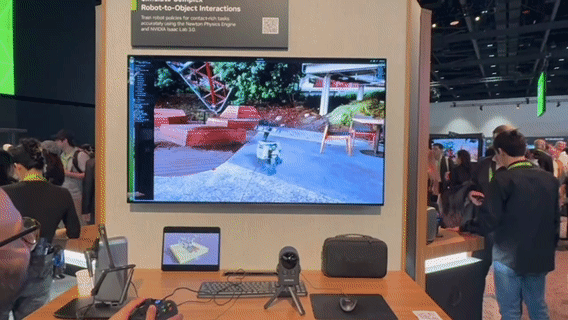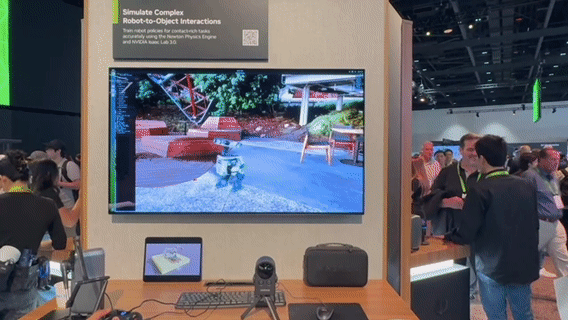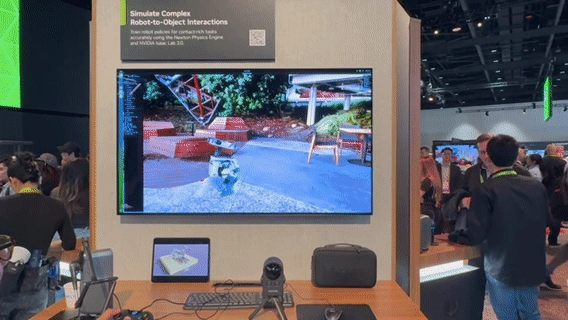
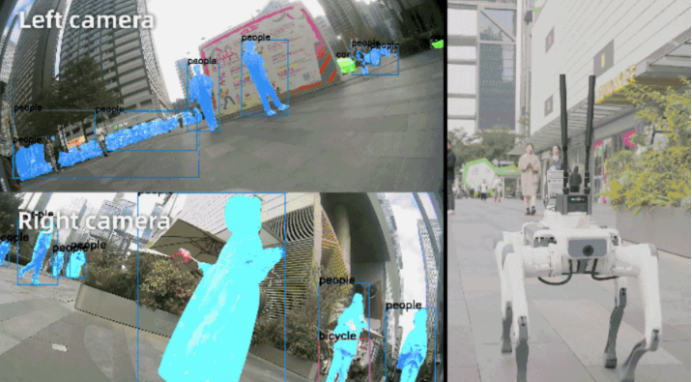
At the NVIDIA Robotics session, XGRIDS demonstrated its solution for embodied AI systems. By deploying spatial perception and modeling on quadruped robot platforms, robots can continuously map and understand their environments, using full 3D spatial structure for path planning, behavioral decision-making, and task execution rather than relying solely on local sensors for immediate obstacle avoidance.
At the AWS partner showcase, XGRIDS presented its Real2Sim pipeline at a systems level — showing how real-world spatial data enters AI training workflows to form a complete loop from environment capture, to world model construction, to simulation training.
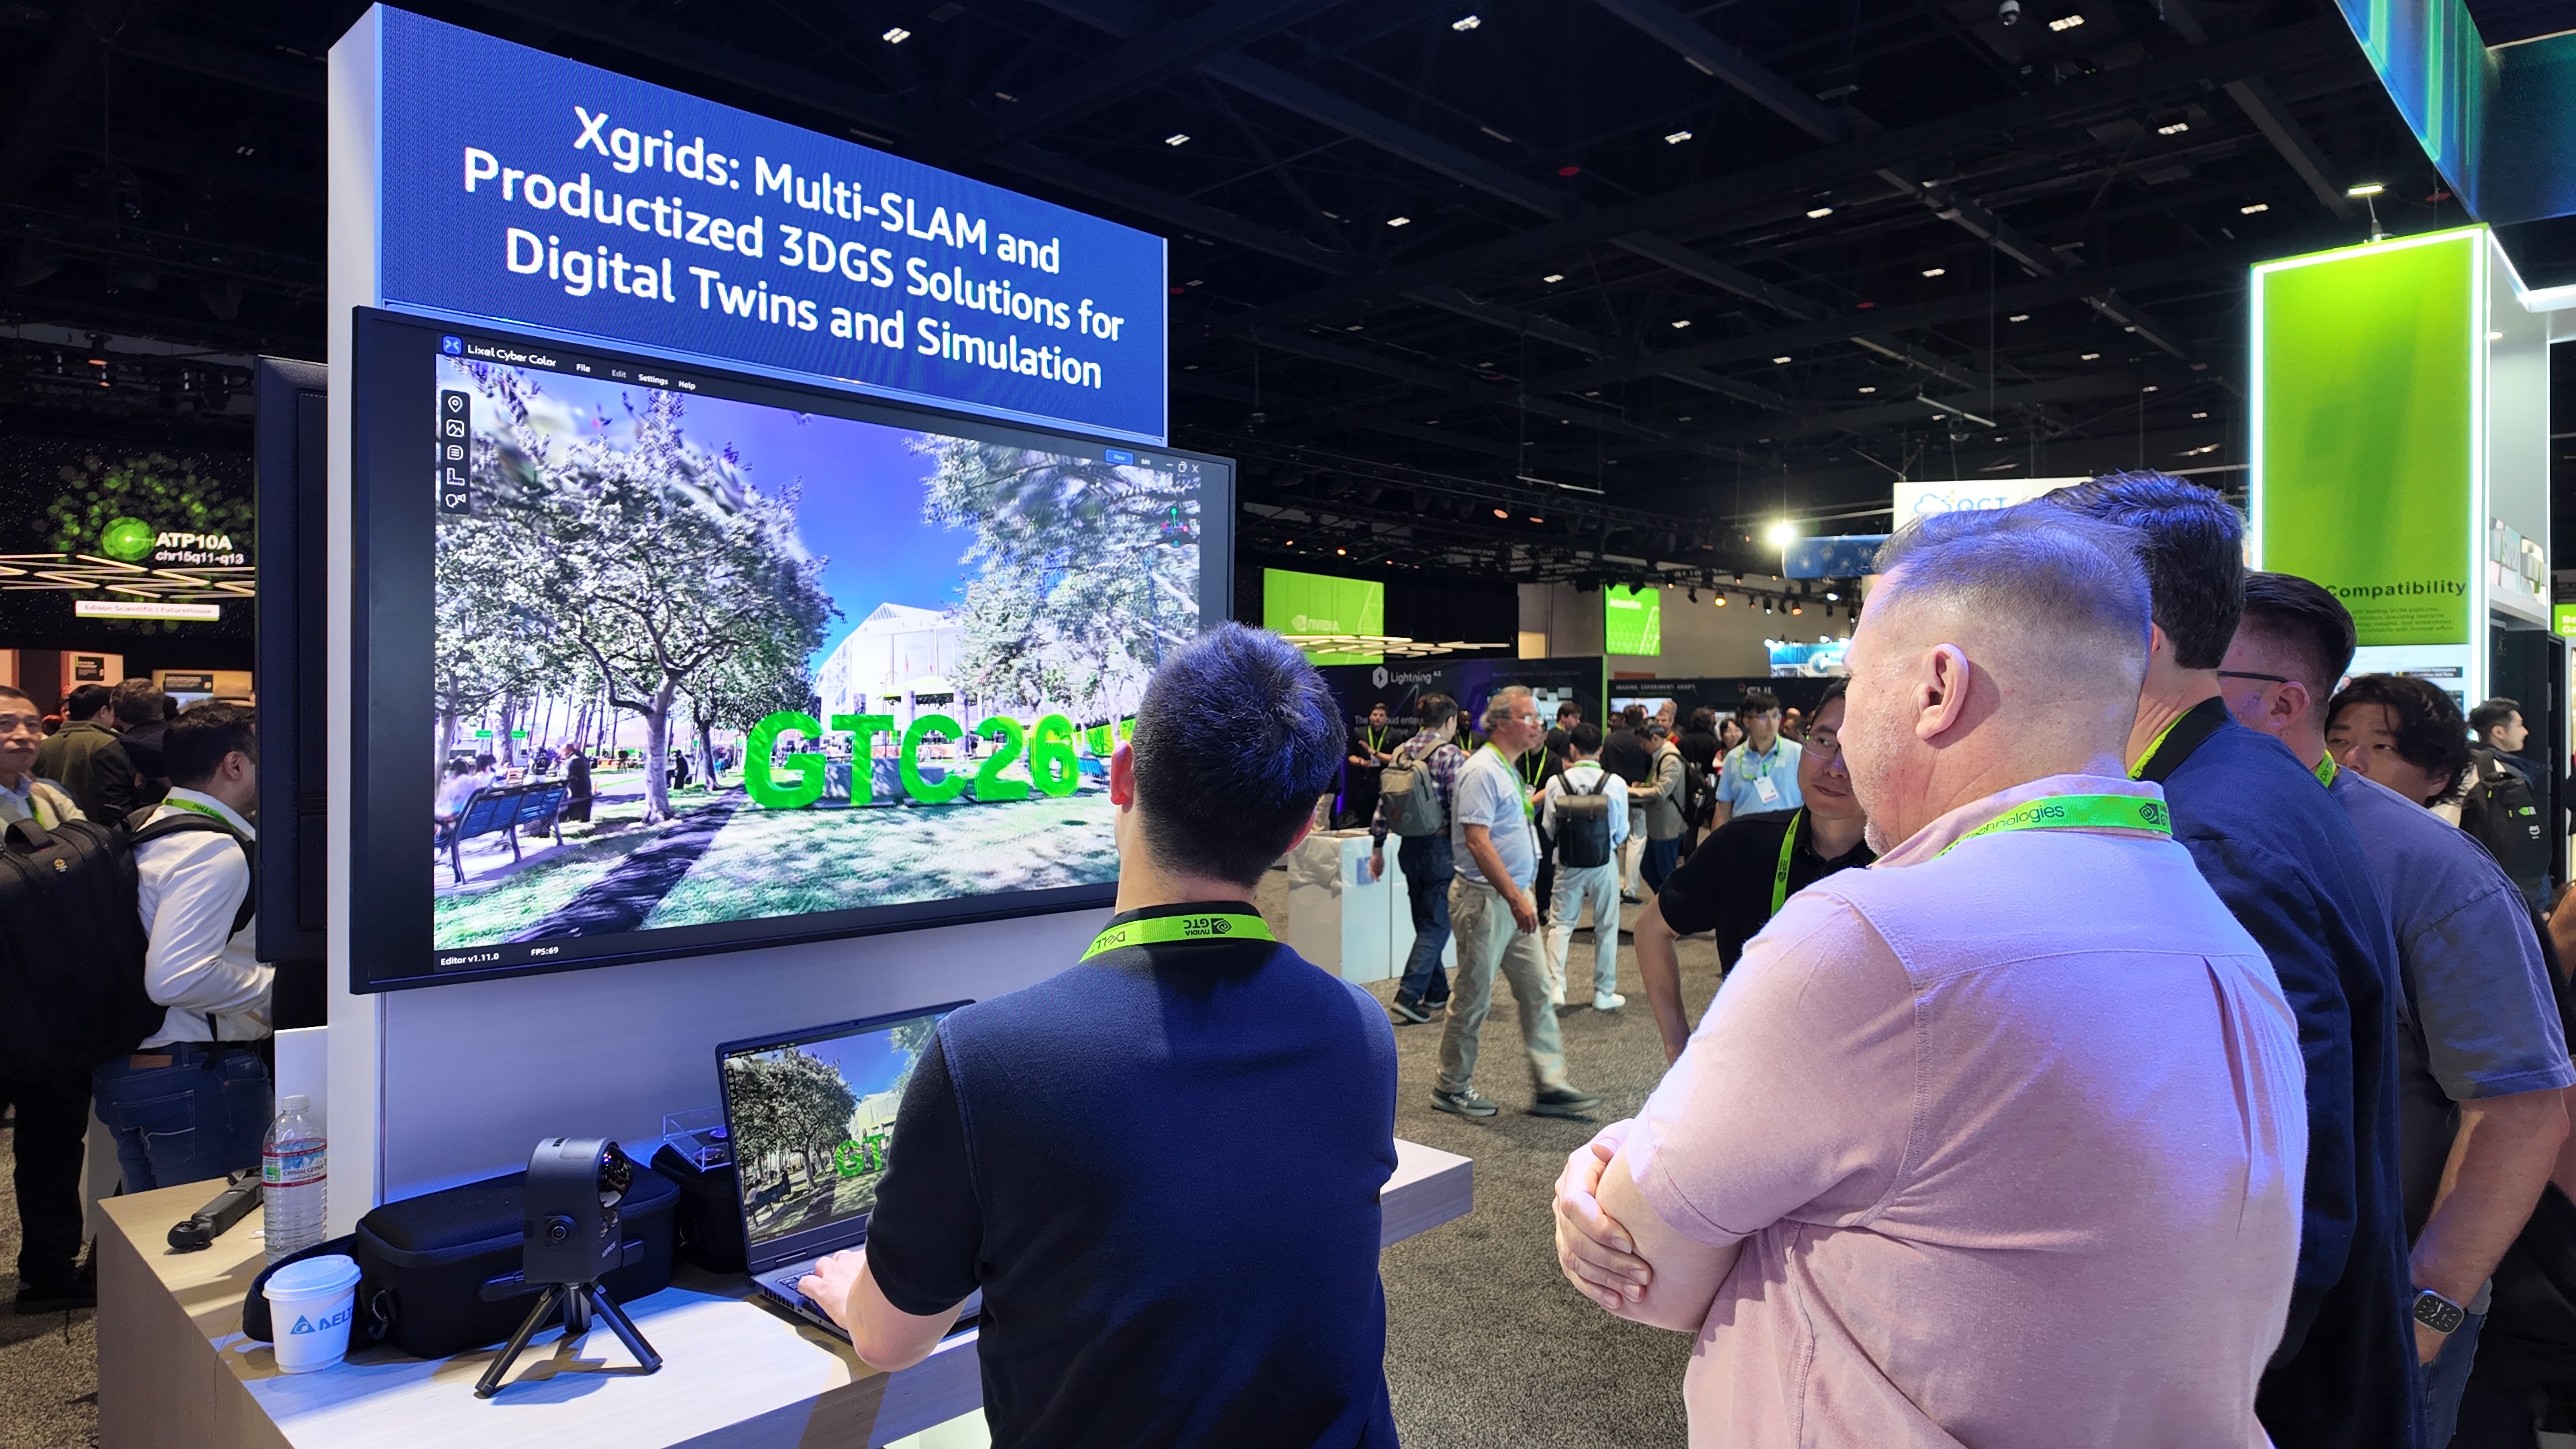
XGRIDS' long-term focus remains consistent: building spatial intelligence infrastructure that converts real-world environments into world models AI systems can understand, reason about, and train on.
GTC 2026 marked a step in bringing this work into the international Physical AI ecosystem, including through collaboration with AWS. As embodied AI systems move from labs into warehouses, cities, and construction sites, the demand for accurate, scalable digital representations of those environments will only grow.
XGRIDS is building the capture-to-simulation layer that makes that possible.
How 3D Gaussian Splatting is closing the gap between spatial capture and in-engine virtual production
Building Accurate, Photoreal 3D Environments for Real-Time Applications
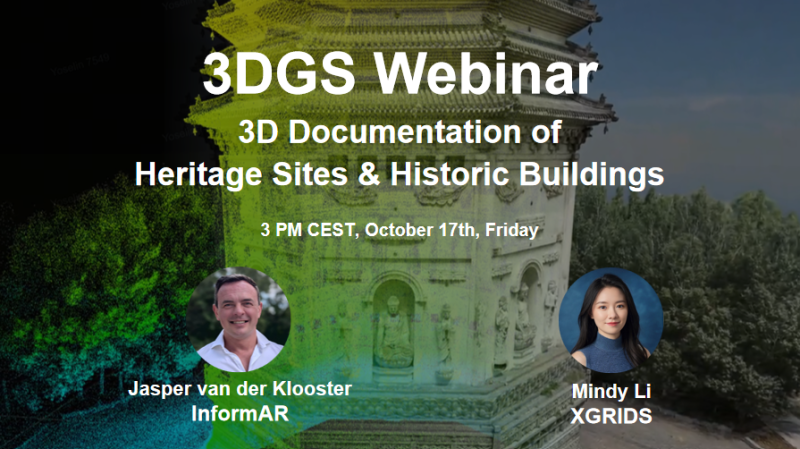
On October 17th, XGRIDS hosted a session in its 3DGS Webinar Series titled "3DGS Documentation for Heritage Sites and Historic Buildings." Featuring Jasper van der Klooster (InformARbv) and Mindy Li (XGRIDS), the webinar explored how point clouds and 3D Gaussian Splatting (3DGS) are redefining the way we document, visualize, and preserve cultural heritage through photorealistic, explorable digital twins.
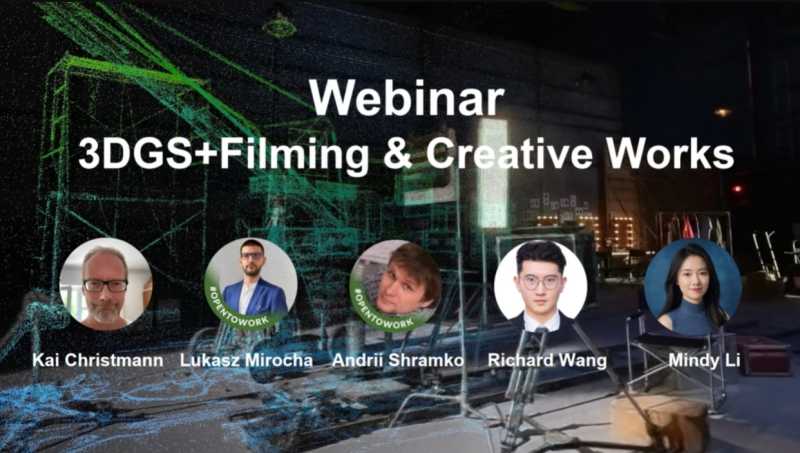
In this webinar, we brought together creators from film, virtual production, and interactive design to explore how 3D Gaussian Splatting (3DGS)—a cutting-edge rendering technique—is being applied across different creative pipelines.